Open source / inspect the work
Make the failure replayable.
A simulation playground, embedded robotics, and teaching material you can try yourself.
A restaurant shift for your Nav2 stack
ANEWS simulates moved tables, chairs, guests and queues in a synthetic restaurant. It connects to an unmodified Nav2 stack over ROS 2 Zenoh, records runs and renders replays. The simulator is the robot, not the planner.
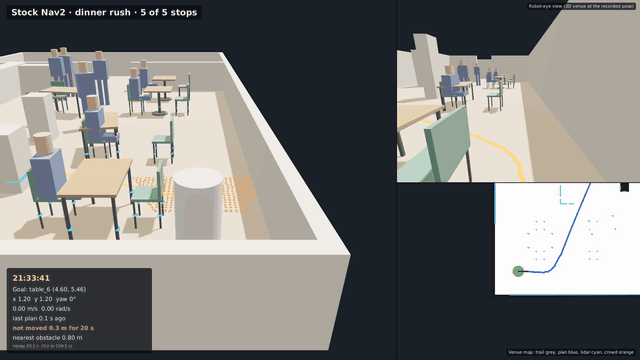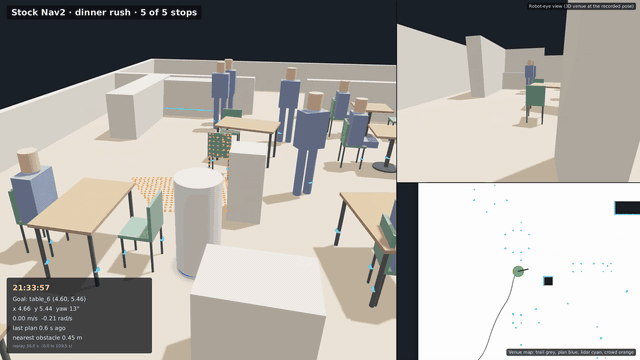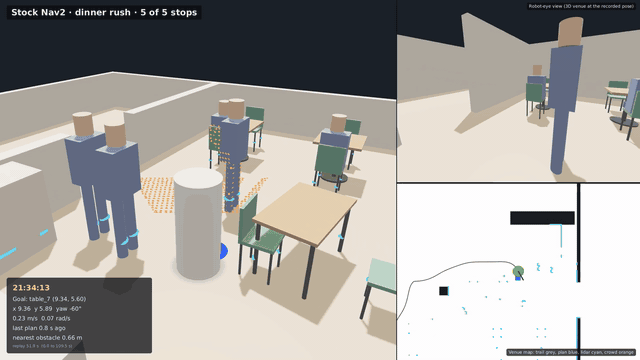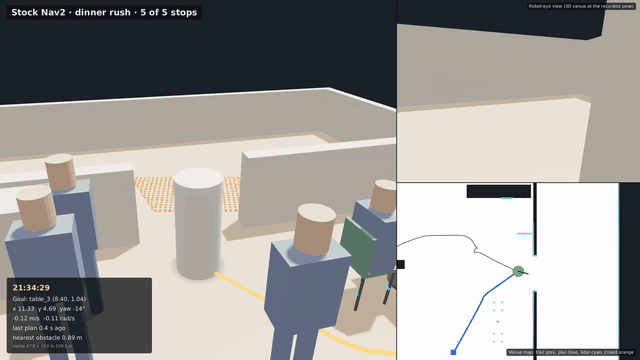
The Docker demo senses on the CPU. For larger runs, ANEWS also supports GPU sensing and rendering. Importing real robot recordings is next on the roadmap.
git clone https://github.com/NelsenEW/ANEWS
cd ANEWS/demo
docker compose up
Read the source and setup requirements ↗
Teaching and embedded robotics
espdrone-ros
The README describes a ROS interface for Espdrone, including messages, sensors, camera utilities and a drone interface, specialised for the NTU EEE UAVIONICS DIP project.
Read the repository ↗EEE-DIP-UAVIONICS
A teaching project covering hands-on electronics, coding and ESP32 cameras before team work. Its README lists Nelsen Edbert Winata and Andrian Huang as instructors.
Read the teaching materials ↗